Description
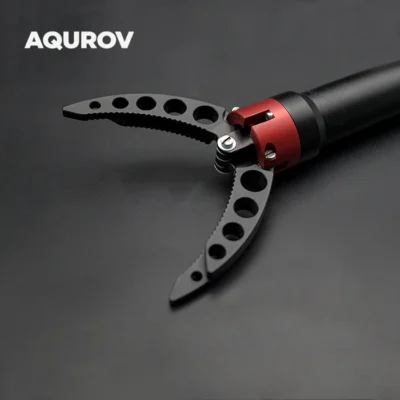
2-DOF underwater robotic gripper
Grip objects and control tool orientation
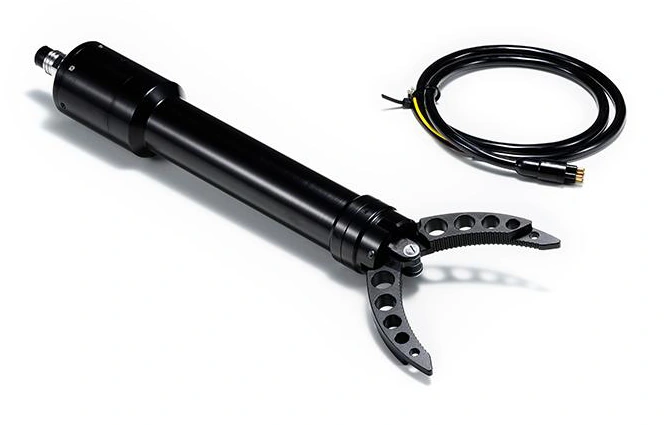
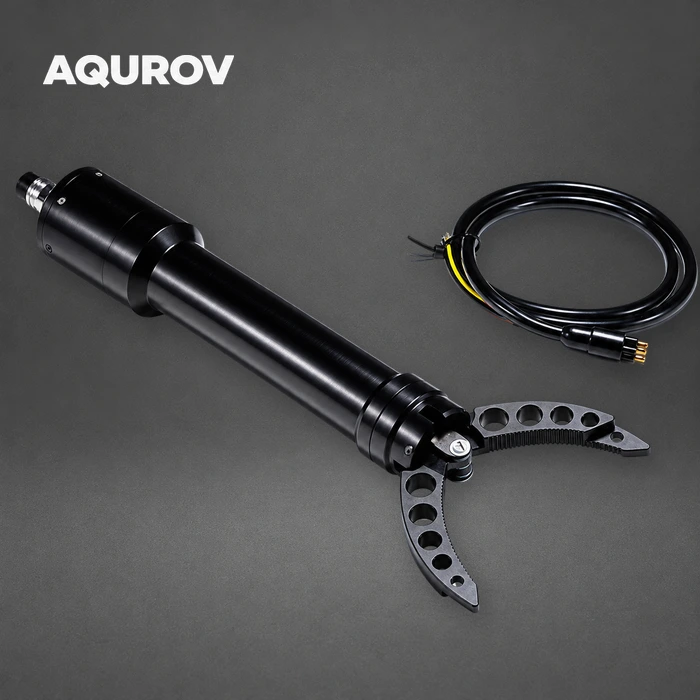
Add object handling to an inspection ROV with a tool that can both grip and rotate. The two functions help position the jaws around a target and adjust their orientation for the task.
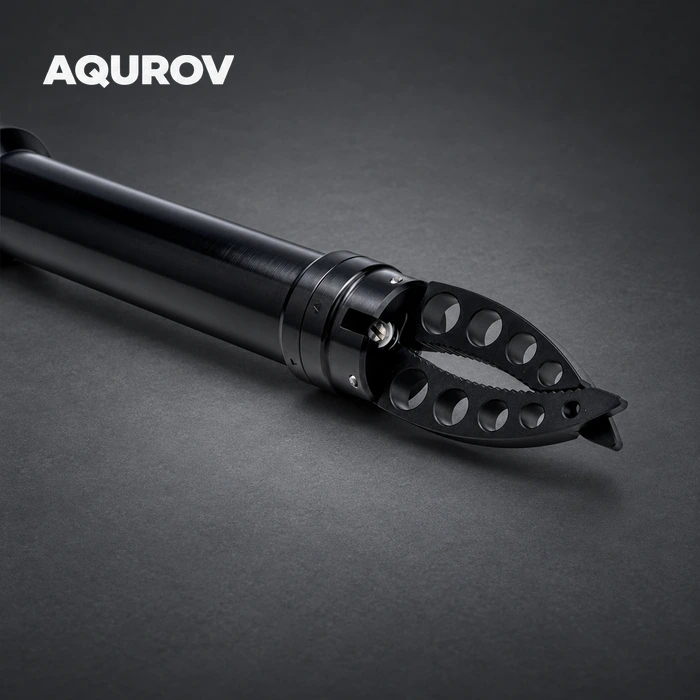
Open and close the jaws
Grasp targets up to 96 mm in diameter with 90–150 N of clamping force at 24 V. A complete opening and closing cycle takes ≤3 seconds.
Rotate the gripper
Change the tool orientation through the rotary function. Separate motor commands provide stop, resume, off and speed control.
Drive, jaws and housing
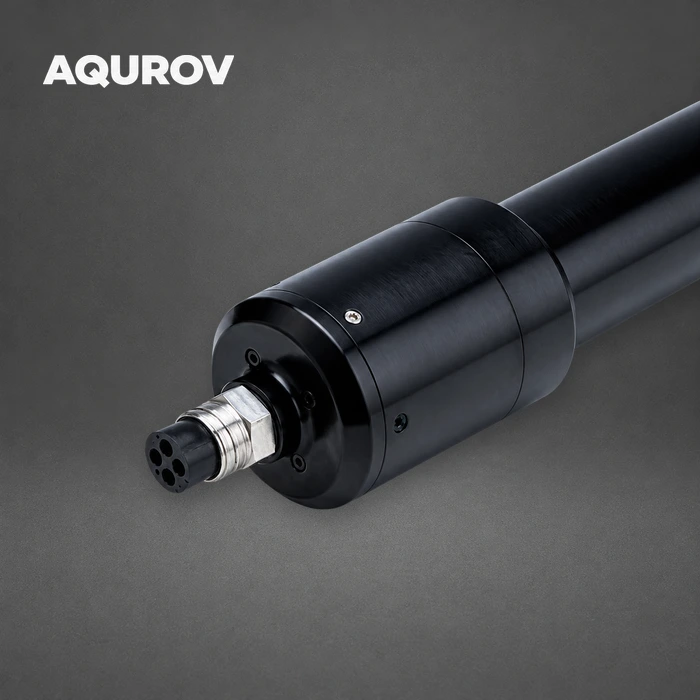
Integrated drive with a four-contact interface
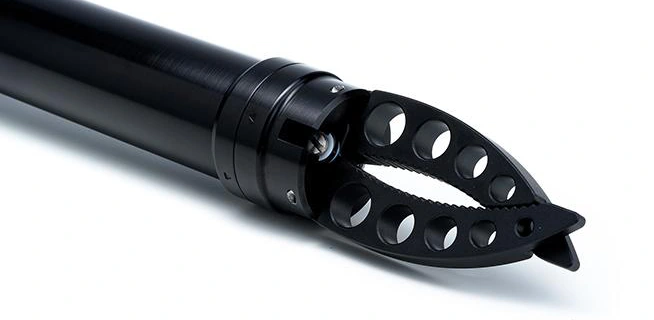
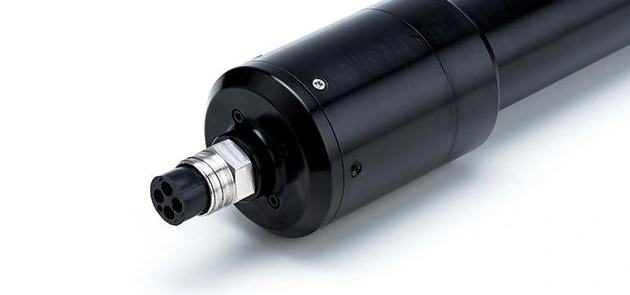
The gripper combines a BLDC brushless planetary gear drive with integrated control, a hardened lead screw and a sealed housing. Torque-adaptive stopping controls the gripping action.
Technical specifications
Product data, separated by function
| Controlled functions | Jaw opening / closing + rotation |
|---|---|
| Rated operating depth | Up to 300 m |
| Clamping force | 90–150 N at 24 V DC |
| Complete opening and closing cycle | ≤3 s |
| Maximum gripped diameter | 96 mm |
| Maximum instantaneous permissible load | 2.4 N·m |
| Weight in air | 1410 g |
| Housing material | Aluminium alloy 6061 |
| Input voltage | 20–25.2 V DC |
|---|---|
| Operating current | 1 A max |
| Communication | RS-485 |
| Baud rate | 115200 bps |
| Cable conductors | 4 × 20 AWG |
| Standard cable length | 1 m |
| Cable outer diameter | 7.5 mm |
| Outer / inner jacket | Black polyurethane / FEP |
| Connection | Four contacts with matching tail connector |
Clamping force is stated in newtons. It is not a rated lifting payload.
Dimensions and installation planning
Millimetres · original engineering views
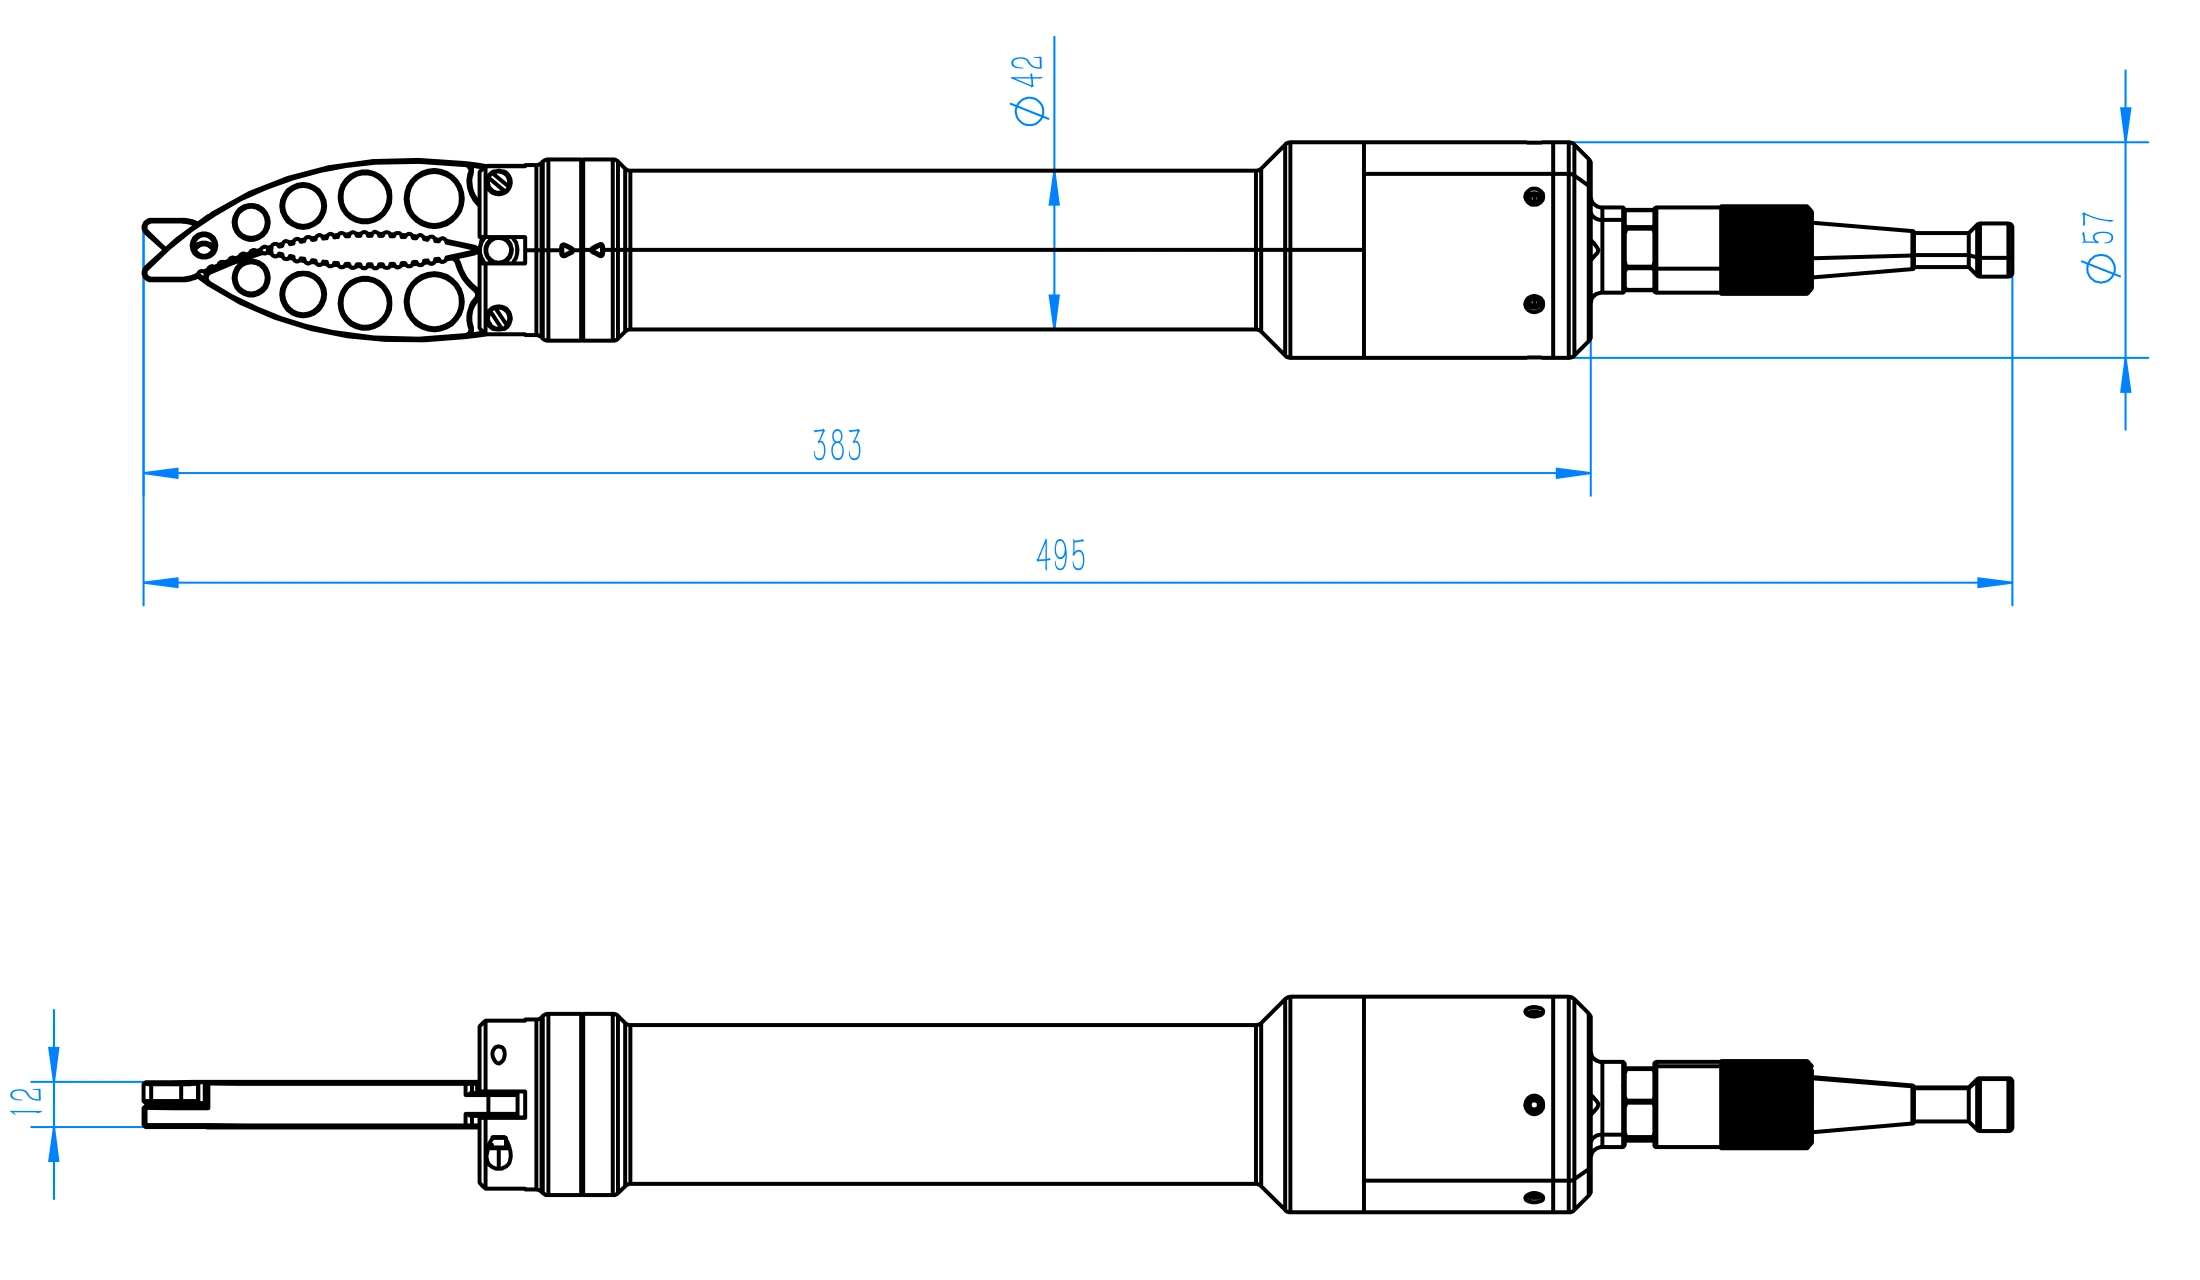
Plan around the full tool envelope
- Use the dimensioned drawing to check the complete assembly, including the rear connector.
- Keep the jaw opening and rotary movement clear of the vehicle frame, cameras and cables.
- Allow room behind the connector for the mating cable and a suitable bend.
- Select the mounting fixture for the vehicle and expected tool loads; the supplied drawing does not define mounting-hole details.
Power and RS-485 wiring
Original connector figure + readable wire definitions
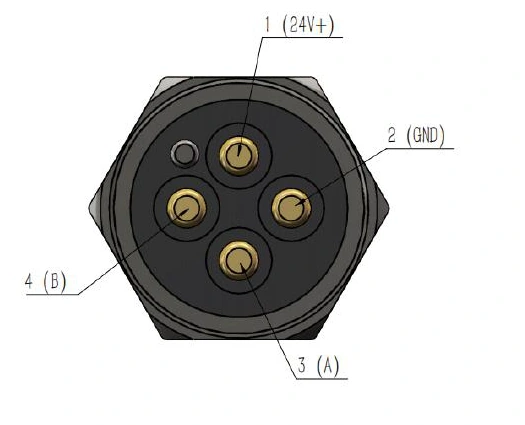
| 1 Red | Positive supply20–25.2 V DC; nominal 24 V |
|---|---|
| 2 Black | GNDSupply ground |
| 3 Yellow | RS-485 ADifferential communication |
| 4 Blue | RS-485 BDifferential communication |
The original connector marks the supply contact “24V+”. The product specification gives the operating range as 20–25.2 V DC.
Control the two functions
Use the encoding specified for each command
Jaw commands
Send the lowercase text command for the required jaw action.
| Open jaws | so |
|---|---|
| Close jaws | sc |
| Stop jaws | ss |
Rotation motor commands
The supplied examples use motor ID 01. Send the command as binary bytes.
View the original HEX command examples
| Motor stop | 3E 81 01 00 C0 |
|---|---|
| Motor run / resume | 3E 88 01 00 C7 |
| Motor off | 3E 80 01 00 BF |
| Positive speed example | 3E A2 01 04 E5 60 EA 00 00 4A |
| Negative speed example | 3E A2 01 04 E5 A0 15 FF FF B3 |
“Motor run” resumes the control mode used before stopping. Positive and negative are the source labels; a clockwise / counterclockwise viewing convention is not specified.
Full speed and position-control details are documented separately. The example motor commands do not establish the assembled tool’s output speed or continuous-rotation capability.
Technical downloads
Engineering drawing, control reference and CAD as separate files
What is included
- 1 × 2-DOF underwater robotic gripper
- Matching 1 m cable with the standard tail connector
Selection and integration FAQ
Practical checks before system integration
What are the two degrees of freedom?
The two controlled functions are jaw opening / closing and rotation of the gripper. They provide grasping and tool orientation.
Is this a PWM gripper?
The supplied documents specify RS-485 at 115200 baud. They provide ASCII jaw commands and binary rotation-motor commands. Use the interface and command reference for this product.
Can it be used on a BlueROV or another ROV?
Plan the mechanical mounting, the 20–25.2 V DC supply and the RS-485 host connection for the vehicle. Compatibility depends on the controller and software implementation; this page does not establish an automatic BlueOS, Navigator or ROS integration.
Does 90–150 N mean a 9–15 kg lifting capacity?
No. The supplied value is clamping force at 24 V. A rated lifting payload requires separate load, orientation and mounting information.
Are custom jaws possible?
The supplied product brochure describes replaceable or custom jaw options. Confirm the jaw geometry and application load requirements for a custom configuration.
Can the gripper rotate continuously?
The available materials do not establish unlimited continuous rotation or a validated output speed. Confirm the required rotation range, cable arrangement and duty cycle for the selected configuration.